Computer Vision, Edge AI & Physical AI Engineering
Physical AI engineering turns intelligence into physical behavior. A robot must interpret its surroundings before it moves. An inspection system must distinguish a defect from a change in lighting. An autonomous device must respond within the limits of its sensors, computing hardware and power supply.
That is the gap Kickmaker helps close. We engineer the physical system around the AI model: computer vision hardware, multimodal sensing, edge AI computing, electronics, embedded software and mechanical integration. We connect perception to a product decision, then test that decision under real operating conditions.
The result is more than a working demonstration. It is an architecture that can be evaluated, refined and prepared for repeated manufacture.
What Physical AI Changes for Hardware Teams
Physical AI, also called embodied AI in robotics, links perception, decision and action in the real world. A camera captures a scene. A model interprets it. The product then moves, alerts an operator, rejects a part or changes its behavior. This is a closed-loop system: each physical action can change what the sensors observe next.
The model is only one part of that loop. Image acquisition takes time. Sensors may disagree or lose calibration. Computing load can raise the device’s temperature. An uncertain output needs a defined response before it reaches an actuator or production line.
Kickmaker turns these dependencies into system requirements. We examine the complete path from sensor signal to physical action, including timing, confidence, degraded states and the conditions under which the product must stop or request human intervention. This gives hardware teams a clearer question than “Does the AI work?”: Does the integrated system behave as intended where it will be used?
Our Physical AI Engineering Capabilities

Computer Vision & Embedded Vision Systems
A computer vision model can only interpret what the product captures. Camera position, optics, field of view, exposure and lighting determine whether an object or defect is visible. Image signal processing and calibration affect how consistently it appears from one device or operating condition to another.
Our engineers design the embedded vision chain around the task. We define camera integration, image acquisition and synchronization requirements, then assess image quality in representative scenes. A machine vision system may need to reveal a small defect at line speed. A mobile robot may need useful images while its viewpoint, lighting and surroundings change.
For applications involving spatial understanding, we also consider how depth sensing or stereo vision contributes to 3D perception. The objective is not to add another sensor by default. It is to capture the information needed for the next decision.
We define that decision interface precisely. A detected object needs a location, timestamp, coordinate frame and confidence level. The downstream system also needs to know what to do when an image is incomplete or a result is uncertain.
Edge AI Hardware & On-Device Inference
Edge AI runs inference on or close to the device. For physical AI products, on-device inference can support decisions without waiting for a remote service. Its usefulness depends on the complete response time, not just the model’s benchmark speed.
Kickmaker evaluates edge AI hardware against the supplied workload and product constraints. The system-on-chip (SoC), neural processing unit (NPU), memory bandwidth and sensor interfaces must support the required image flow. We measure inference latency alongside acquisition, preprocessing and the communication of results. We also consider startup time, power consumption and thermal behavior inside the intended enclosure.
This is hardware-software co-design: the model’s input and computing needs inform electronics and mechanical choices, while the target hardware sets practical limits on the deployed model. If adaptation is needed, we assess model compression options using FP16 or INT8 reduced precision. We check their effect on both device performance and task results. A faster model is not an improvement if it misses the event the product exists to detect.
Sensor Integration & Sensor Fusion
Physical interaction often requires more than vision. Depth sensors can establish distance and geometry. Inertial sensors can help interpret motion. Tactile sensing can indicate contact when an object is grasped. Multimodal perception combines observations that answer different parts of the same physical question.
Our teams define each sensor’s role before integrating it. We address mounting, calibration, coordinate frames and time synchronization so that signals describe the same event. Sensor fusion is then evaluated against a product decision: does the additional information reduce uncertainty, or does it merely add cost and complexity?
Consider a robotic grasp. Vision can guide the approach, while tactile feedback can help confirm contact. The value lies in how those signals reach the decision and control functions at the right time. Kickmaker engineers the physical and electronic interfaces that make this behavior observable and testable.
Physical AI Data: Synthetic Data & Field Validation
A system can perform well in a controlled demonstration and still struggle in service. Reflections, occlusions, unfamiliar objects, worn components and sensor drift create domain shift: the field no longer looks like the conditions used to evaluate the model. Rare or unexpected scenes are particularly important when an incorrect decision has a physical consequence.
Synthetic data and a digital twin can help a model team explore scenarios that are difficult to reproduce. They cannot replace measurements from the integrated product. The sim-to-real gap must be examined with its actual sensors, optics, mechanics and computing hardware.
Kickmaker designs for this evidence. We define what the device should capture, how configurations and calibration are recorded, and which edge cases need physical tests. We compare expected and observed system behavior, then provide the findings to the client and its model team. That feedback can guide changes to the hardware, the operating envelope or the model without confusing product validation with model training.
Design for AI: Hardware Decisions Start With the Model
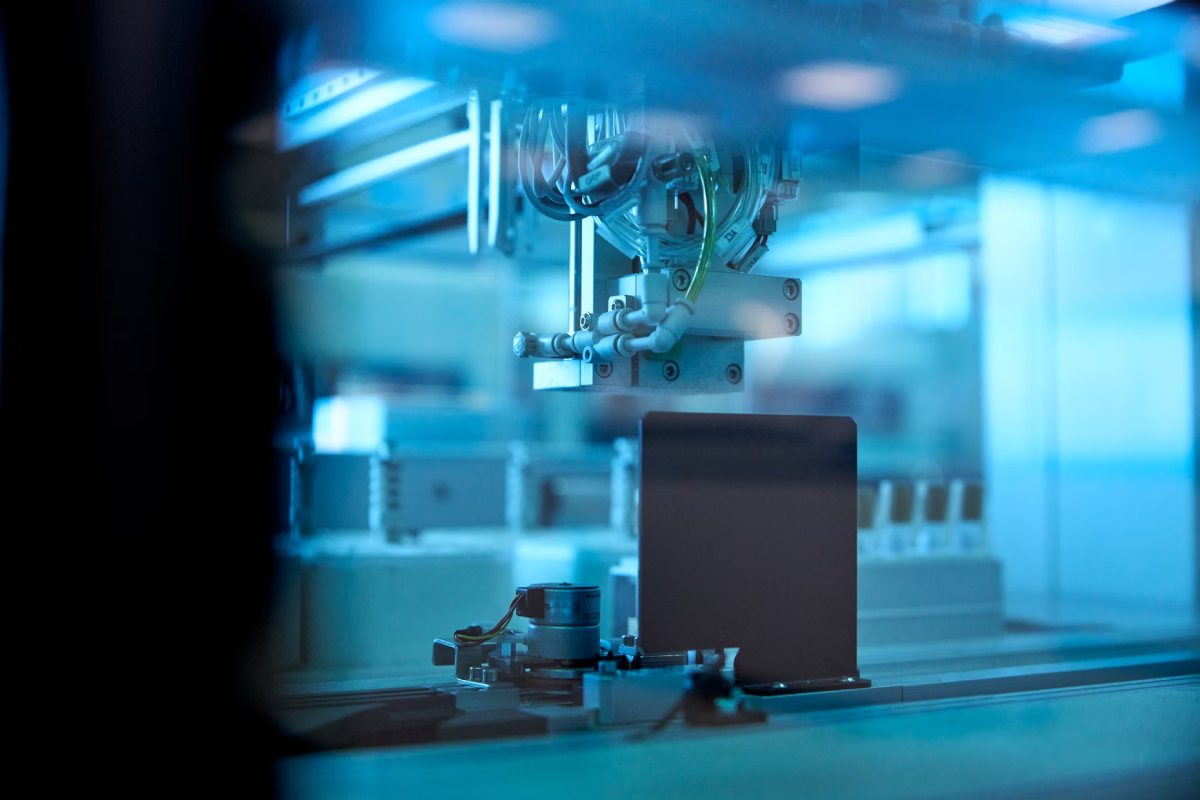
An AI workload shapes the product before its electronics layout or enclosure is fixed. Input resolution affects camera choice and data bandwidth. Inference frequency affects compute, memory and power. Heat from the processor influences packaging. Sensor placement can determine whether the required scene is visible at all.
Kickmaker translates these needs into a physical AI system architecture. We assess the relationship between perception quality, response time, energy use, bill of materials and manufacturability. We also plan access for calibration and the tests needed to check each manufactured unit.
Emerging vision-language-action (VLA) models make this system boundary even more important. A model may interpret images and instructions to propose an action, but the product still needs defined interfaces to its motion or control system. Timing, observable outputs, operating limits and safety responsibilities cannot be left implicit.
Our role is to engineer and test those interfaces around the model supplied by the client or its AI partner. Clear boundaries also make it easier to evaluate a future model change without redesigning every part of the product.
Meet the engineers behind the expertise
In computer vision and AI, the real challenge is turning complex visual data into reliable, actionable decisions. At Kickmaker, we take an end-to-end approach to every project, accounting for the product’s real-world operating conditions. What I enjoy most is analyzing input data and algorithm outputs to identify biases and understand how the algorithms behave.

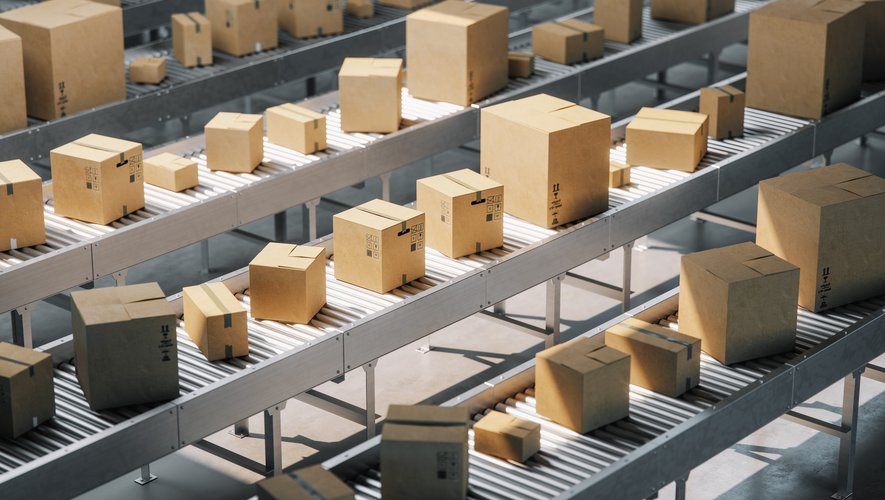
La Poste : Optimizing Manual Parcel Sorting and Scanning Operations
La Poste has developed an AI-powered mobile application capable of reading addresses and scanning parcels through image analysis to speed up and improve the reliability of sorting and delivery operations.
-
Where We Deploy Physical AI
-
Humanoid & Autonomous Robots
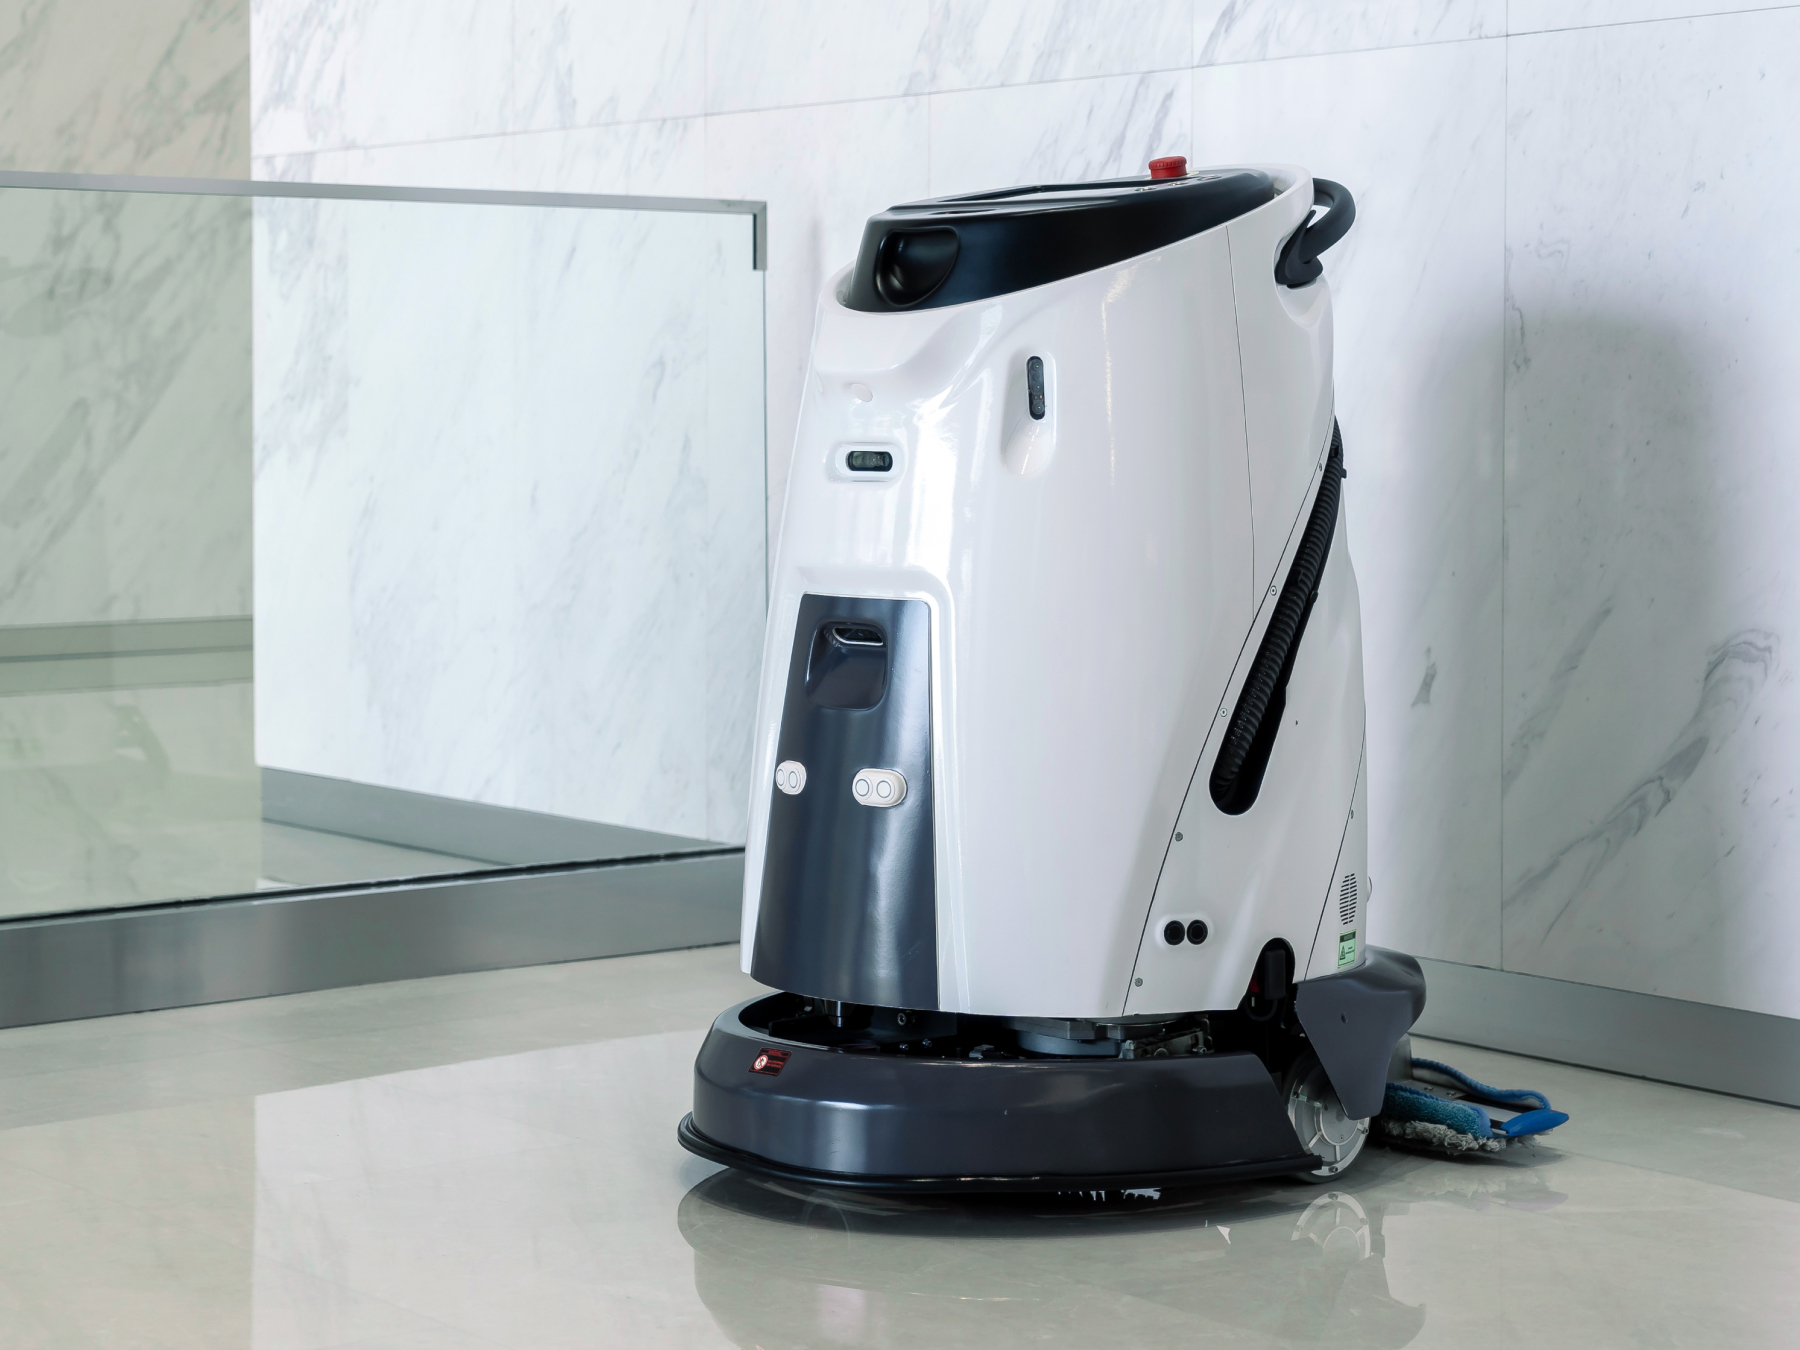
Humanoid robots, autonomous mobile robots and other intelligent machines operate in changing physical spaces. Their robotic perception must remain useful as the machine moves, encounters people or faces an unfamiliar scene.
Kickmaker designs the architecture for these interactions, from mechatronics through to physical AI. We examine what the machine needs to observe, how quickly it must respond and which interfaces connect perception to action. The intended operating conditions and safety responsibilities determine what must be tested; a successful lab demonstration cannot define them alone.
-
Industrial Inspection & Quality Control
Industrial inspection applies machine vision to a production decision. Lighting, part presentation, vibration and material variation can all affect whether a defect is visible. False rejections and missed defects have different consequences for throughput and quality.
We design the camera and edge AI hardware as part of the inspection system. We define acquisition conditions, the interface to machine control and the handling of uncertain results. Performance can then be evaluated against the client’s actual parts and operating conditions, rather than a generic image dataset.
-
Logistics & Warehouse Automation
A warehouse changes throughout the day. Loads move, routes are obstructed and lighting varies. Autonomous equipment therefore needs perception that remains useful while both the machine and its environment change.
Kickmaker integrates embedded vision, depth sensing and on-device inference within the product’s electrical, mechanical and energy constraints. We test relevant scenarios and use the findings to refine the architecture before repeated builds or operational deployment.
Physical AI FAQ
What is physical AI?
Physical AI describes systems that use AI to perceive and act in the physical world. Their behavior does not depend on the model alone: sensors, computing hardware, software, mechanics and operating conditions all matter.
Is embodied AI the same as physical AI?
The terms overlap. Embodied AI often emphasizes intelligence situated in a body, such as a robot. Physical AI can also describe other products that connect perception and decisions to real-world actions, including autonomous machines and inspection systems.
What is the difference between edge AI and physical AI?
Edge AI describes where inference runs: on or near the device. Physical AI describes what the complete system does in the real world. A physical AI product may use edge AI to make decisions close to its sensors and actuators, but it may also use external cloud resources, such as virtual machines or data storage buckets, when the application calls for them.
Does Kickmaker develop AI models?
This expertise focuses on engineering the product around the model. Kickmaker works on sensing, edge computing, embedded integration, physical validation and industrialization. The client or its AI partner retains responsibility for developing and training the model.
How do you evaluate a model for an embedded physical AI product?
We assess the supplied model as part of the complete device. The relevant evidence includes task errors, sensor conditions, memory use, power, thermal behavior and the time from observation to product response.
How do you reduce the sim-to-real gap?
We compare simulated scenarios with data and behavior measured on the integrated product. Differences in optics, lighting, geometry, timing or physical interaction become test cases. The results inform system changes and give the model team evidence for further work.
Talk to us and see what’s possible
Tell us about your product, its current stage, and the challenge ahead. We’ll discuss your priorities and identify where our team can help you take the next step.
"*" indicates required fields